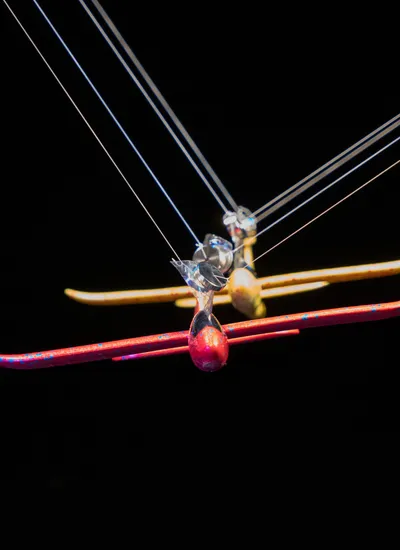
Choreographing Cable Robots with Madeline Gannon
ROB|ARCH
Description
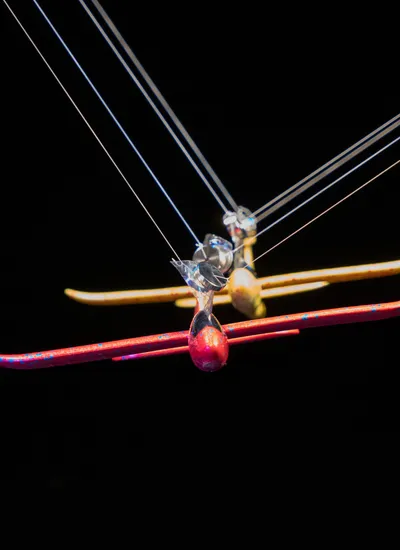
This workshop invited attendees to discover the anatomy, affordances, and creative opportunities that cable‑driven robots can bring to architectural robotics. These under‑explored machines can be combined to span larger spaces, lift heavier loads, and move as precisely as industrial robots. However, their use has been limited because no off‑the‑shelf hardware solution existed, and they were difficult to simulate and control.
During the workshop, a fleet of custom‑built cable robots, interactive control software, and sensors were brought to Toronto to teach participants how cable robots could be combined to create engaging 1D, 2D, and 3D motion. Each attendee learned how to connect their preferred development environment—such as Rhino/Grasshopper, Processing, TouchDesigner, Blender, Unity, Unreal Engine, Python, or C++—to directly control the cablebots, and created a unique interactive experience to share with the group.
Attendees left the workshop understanding the core design principles and challenges of working with cable‑driven robots, along with a suite of tools and workflows for creating intuitive, interactive interfaces for their own use cases.
Website
ROB|ARCHFood & Drink
Food and drink aren't permitted in the theatre. The exception is a show with a bar or concession running — when there is one, we'll say so on the event page.
From the Stage